SG-8021 Integrated Planetary Robot Joint Actuator
Product Overview
SG-8021 is a low-profile planetary robot joint actuator designed for humanoid robots, quadruped robots, robotic arms, exoskeletons and compact automation systems.

Available configurations:
- Motor + planetary gearbox + integrated driver + encoder
- Motor + planetary gearbox without integrated driver, with the final sensor and cable configuration confirmed by order
Product Identity
| Item | Description |
|---|---|
| Model | SG-8021 |
| Product type | Integrated planetary robot joint actuator |
| Transmission | Planetary gearbox |
| Recommended use | Robot joints and compact rotary actuators |
Key Benefits
- 100 mm outer diameter with a 42.6 mm low-profile body
- 10 Nm rated torque and 30 Nm peak torque
- 160 rpm rated output speed
- 15-20 arcmin backlash
- Optional integrated driver and absolute-encoder control platform
Key Specifications
| Parameter | Value |
|---|---|
| Transmission structure | Planetary gearbox |
| Outer diameter | 100 mm |
| Thickness | 42.6 mm |
| Reduction ratio | 9.25:1 |
| Backlash | 15-20 arcmin |
| Operating voltage | 24-48 VDC |
| Motor power | 213 W |
| Rated speed | 160 rpm |
| No-load speed | 240 rpm |
| Rated torque | 10 Nm |
| Peak torque | 30 Nm |
| Weight | 671 g |
| Allowable radial force | 1300 N |
| Allowable axial force | 550 N |
Peak Torque Condition
Peak torque: 30 Nm
Peak duration: Subject to operating voltage, current limit and thermal conditions.
Mechanical Dimensions
The standard product drawing shows a nominal outer diameter of 100 mm and a nominal body thickness of 42.6 mm. Detailed mounting dimensions, tolerances and interface drawings are supplied after inquiry and engineering review.
Transmission Parameters
| Parameter | Value |
|---|---|
| Reduction ratio | 9.25:1 |
| Backlash | 15-20 arcmin |
| Transmission type | Planetary structure |
Motor and Electrical Parameters
| Parameter | Value |
|---|---|
| Motor power | 213 W |
| Operating voltage | 24-48 VDC |
| Phase inductance | 290 uH |
| Phase current full scale | 33 A |
| Rated bus current | 12 A |
| Static working bus current | 0.08 A |
| Motor torque constant | 0.046 Nm/A |
| Motor structure | 21 pole pairs |
| Thermistor | 10 kOhm, B3435, +/-1% |
| Back-EMF constant | 0.143 Vs/rad |
| Motor speed constant | 63 rpm/V |
Encoder and Sensor
The driver-equipped configuration uses the SigGear integrated driver and absolute-encoder control platform. Final encoder, sensor and cable configuration must be confirmed in the quotation and order documentation.
Driver and Control
For the driver-equipped version, available functions include:
- FOC closed-loop control
- Position control
- Velocity control
- Torque control
- MIT-style motion control
- PID parameter configuration
- Calibration and user-zero configuration
These functions apply only to the driver-equipped configuration.
Communication Interfaces
Standard on the driver-equipped configuration:
- CAN
- USB Type-C for debugging and configuration
Optional or project-specific:
- RS485 through expansion hardware
- EtherCAT solution subject to project evaluation
- Additional expansion interfaces subject to engineering confirmation
Load Capacity
| Parameter | Value |
|---|---|
| Allowable radial force | 1300 N |
| Allowable axial force | 550 N |
Actual load suitability depends on mounting structure, load direction, duty cycle, shock load and bearing-life requirements.
Standard Configuration
Standard configuration is confirmed by quotation and may include:
- SG-8021 motor and planetary gearbox assembly
- Integrated driver and encoder when selected
- Standard cable or connector configuration
Optional Configuration
- Version without integrated driver
- RS485 expansion
- Custom cable length and connector
- Mechanical interface customization
- Customer branding and label customization
What Is Not Included
Unless specifically stated in the quotation, the following are not included:
- Robot-side mounting structure
- External power supply
- Host controller
- Custom communication gateway
- Application-specific cooling structure
Recommended Applications
- Humanoid robot joints
- Quadruped robot joints
- Robotic arms
- Exoskeleton joints
- Compact automation rotary axes
Product Images
Front-angle product view
Internal planetary transmission and driver view
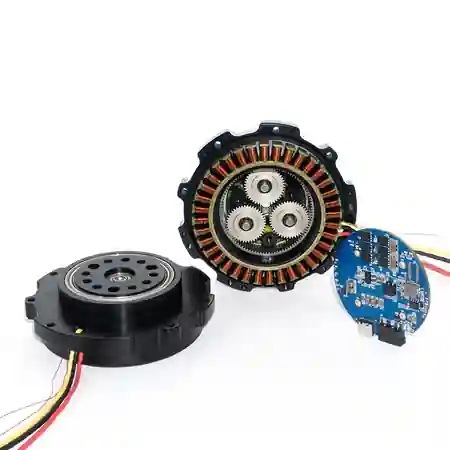
The exploded photograph illustrates the motor, planetary transmission and a driver-board configuration. Final electronics, encoder, cable and connector configuration must be confirmed in the quotation.
CAD and Drawings
STEP models, 2D drawings, detailed mounting drawings and interface documents are available upon request. Please include your application, required torque, speed, voltage, estimated quantity and preferred configuration.
Request CAD Files: wangwanrong@siggear.com
Public Engineering Resources
SG-8021 Technical Datasheet v1.0 Mechanical Interface Reference v1.0
These public references consolidate the specifications already published on this product page. A public STEP model is not currently released in this repository; request configuration-matched CAD and controlled drawings for final design-in.
Selection Information Required
Please provide:
- Application and installation position
- Rated and peak torque
- Required output speed
- Operating voltage
- Size and weight limits
- Duty cycle
- Driver and communication requirements
- Estimated sample and annual quantity
Related Selection and Application Guides
Custom Robot Joint & Compact Actuator Development Robot Joint Actuator and Gearbox Selection Guide Humanoid Robot Joint Actuators and Gearboxes Robotic Arm Joint Actuators and Gearboxes Exoskeleton Joint Actuators and Gearboxes Request CAD, Sample and Quote
Contact SigGear
Wanrong Wang
International Sales, SigGear
wangwanrong@siggear.com