SG-6010D Integrated Planetary Robot Joint Actuator
Product Overview
SG-6010D is an integrated planetary robot joint actuator designed for humanoid robots, quadruped robots, robotic arms and exoskeleton applications.
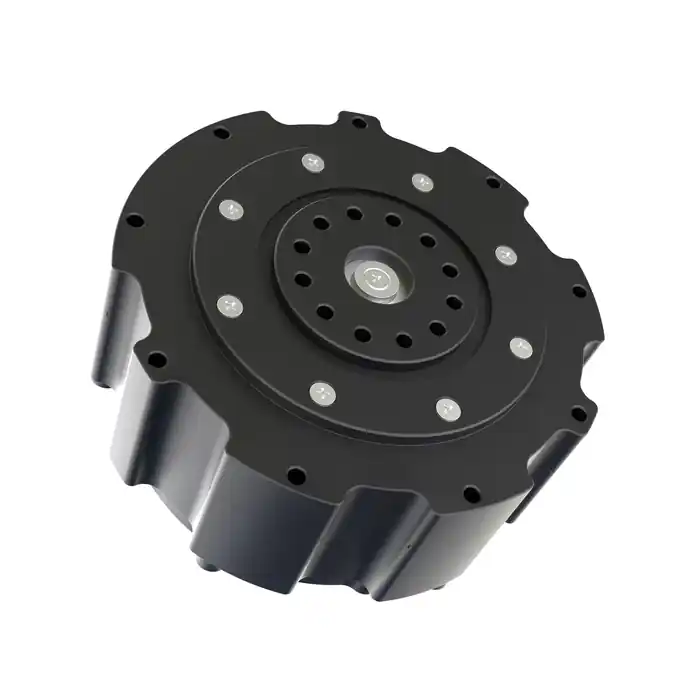
Available configurations:
- Motor + planetary gearbox + integrated driver + encoder
- Motor + planetary gearbox without integrated driver (configuration confirmed by order)
Engineering Evaluation Fast Track
SG-6010D can be evaluated as a complete planetary robot joint actuator or as a reference platform for a project that needs a different torque-speed balance, mechanical interface or control configuration.
If your joint requirement does not match the published 80 mm / 28.13:1 configuration, send the joint position, required torque and speed, installation envelope and the motor / controller information already defined.
Custom Robot Joint Development Robot Joint Selection Guide Request CAD, Sample and Quote
Key Specifications
| Parameter | Value |
|---|---|
| Transmission structure | Planetary gearbox |
| Outer diameter | 80.0 mm |
| Thickness | 58.77 mm |
| Reduction ratio | 28.13:1 |
| Backlash | 15-30 arcmin |
| Operating voltage | 24-48 VDC |
| Motor power | 328 W |
| Rated speed | 100 rpm |
| No-load speed | 170 rpm |
| Rated torque | 16 Nm |
| Peak torque | 50 Nm |
| Weight | 791 g |
| Allow radial force | 1000 N |
| Allow axial force | 400 N |
Peak Torque Condition
Peak torque: 50 Nm
Peak duration: Subject to operating voltage, current limit and thermal conditions.
Encoder, Driver and Communication
SigGear has confirmed that the current SG6010 driver platform documented in the SG6010 user manual applies to the driver-equipped SG-6010D configuration.
Confirmed functions include:
- MA600 16-bit single-turn absolute magnetic encoder
- FOC closed-loop control
- Position, velocity, torque and MIT-style motion control
- CAN Simple
- CANopen (CiA301 / CiA302 / CiA402)
- USB Type-C debugging / configuration
- RS485 / Modbus RTU when the corresponding interface / expansion configuration is supplied
EtherCAT and other expansion interfaces remain project-specific and require confirmation.
| Confirmed driver reference | Value |
|---|---|
| SG6010 driver platform protocols | CAN Simple / CANopen / RS485 Modbus RTU |
| Driver encoder resolution | 16-bit single-turn absolute |
| Driver rated voltage | 15~48 V DC |
| Driver CAN maximum bitrate | 1 Mbps |
Driver and Communication Reference
Product Images
Front-angle view
Driver and interface side

The photographs show a driver-equipped product configuration. Final driver, encoder, connector and cable configuration must be confirmed in the quotation.
Public Engineering Resources
SG-6010D Technical Datasheet v1.0 Mechanical Interface Reference v1.0 Driver and Communication Reference v1.0
CAD and Technical Files
A public STEP model is not currently released in this repository for SG-6010D. Detailed STEP models, controlled drawings and configuration-specific integration files are available after application review and inquiry.
Selection Information Required
Please provide:
- Application and installation position
- Rated and peak torque
- Required peak-torque duration
- Required output speed
- Operating voltage
- Size and weight limits
- Duty cycle
- Radial and axial loads
- Driver, encoder and communication requirements
- Estimated prototype and annual quantity
Related Selection and Application Guides
Custom Robot Joint & Compact Actuator Development Robot Joint Actuator and Gearbox Selection Guide Humanoid Robot Joint Actuators and Gearboxes Robotic Arm Joint Actuators and Gearboxes Exoskeleton Joint Actuators and Gearboxes Request CAD, Sample and Quote
Contact
Wanrong Wang
International Sales, SigGear
wangwanrong@siggear.com