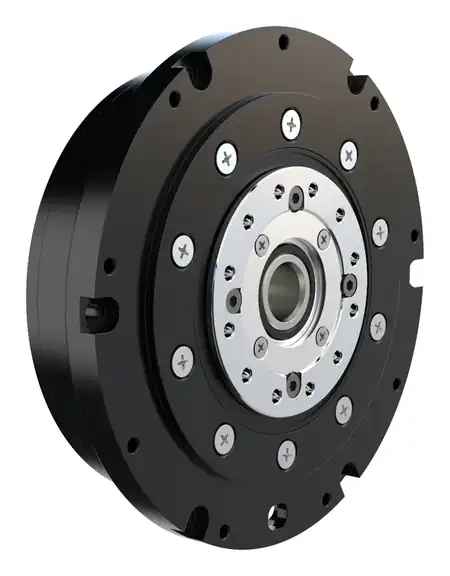
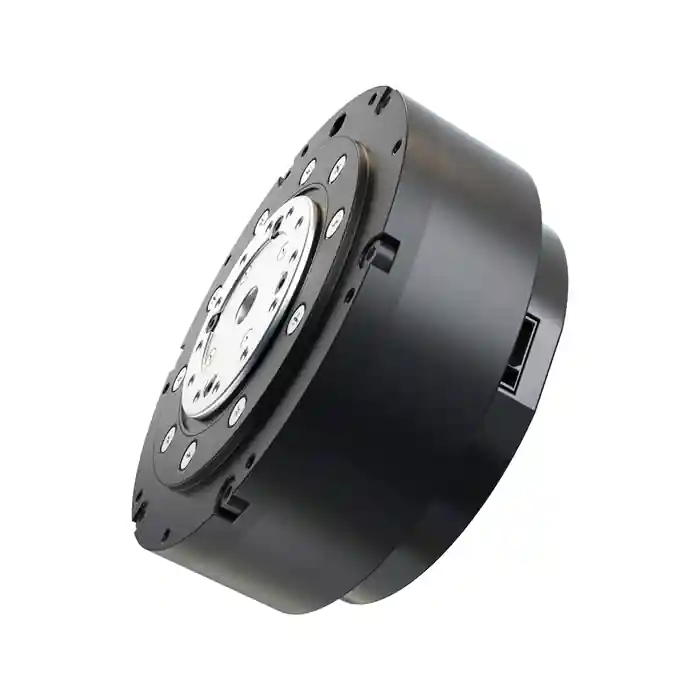
CPM-100-25 | Cycloidal Robot Joint Module
Download Files
| File | Configuration / Release Status | Direct Download |
|---|---|---|
| Datasheet PDF | CPM-100-25 · Public base reference Rev 0.1 | Download PDF |
| 2D installation drawing | Standard 29.5 mm variant · not publicly released | Request controlled drawing |
| 2D reference PDF | SG2556D Dual Encoder + Driver · 48 mm only | Download 2D PDF |
| Original full-assembly STEP | Standard / no integrated driver · 29.5 mm | Download STEP |
| Original full-assembly STEP | Dual encoder + driver · 48 mm | Download STEP |
Need a custom joint configuration? Review my mechanism / STEP · Custom robot joint development · Encoder / driver / communication review · Prototype → volume
These public model files are a reference platform, not the limit of SigGear's custom joint capability.
Public engineering files are for evaluation. A reference 2D PDF is not a revision-controlled manufacturing drawing. Confirm the matching interface and ordered configuration before production.
Mechanical Interface · All 6 Joint Module Downloads
Key Specifications
| Specification | Published value |
|---|---|
| Outer Diameter | 100 mm |
| Product Thickness | 29.5 mm |
| Reduction Ratio | 25:1 |
| Backlash | 5-10 arcmin |
| Operating Voltage | 24-48 VDC |
| Rated Output Speed | 60 rpm |
| Rated Output Torque | 25 Nm |
| Peak Output Torque | 75 Nm |
Full published parameter table
| Additional specification | Published value |
|---|---|
| Transmission Structure | Cycloidal pinwheel |
| Rated Motor Power | 213 W |
| No Load Output Speed | 90 rpm |
| Weight | 630 g |
| Allowable Radial Force | 500 N |
| Allowable Axial Force | 300 N |
Variant-specific parameters (not standard for every configuration)
| Variant item | Value |
|---|---|
| Dual encoder variant code | SG2556D |
| Dual encoder variant outer diameter | 100 mm |
| Dual encoder variant axial dimension | 48 mm |
| Dual encoder variant rated voltage | DC 48V |
| Dual encoder variant rated speed | 60 RPM |
| Dual encoder variant rated torque | 25 Nm |
| Dual encoder variant no-load speed | 125±10% RPM |
| Dual encoder variant no-load current | 1.1 A |
| Dual encoder variant weight | 853 g |
Configuration: Driver, encoder and interface features depend on the selected ordered variant. Rated ≠ peak: Peak torque is not a continuous rating. The downloadable PDF is a public reference summary, not a production-controlled specification. Verify mounting dimensions, duty cycle and electrical configuration before design-in.
Detailed technical reference · Dual-encoder variant · All six joint modules