32 mm Miniature Planetary Gearhead (32P)
Download Datasheet PDF Download 2D Drawing PDF Download Full Assembly STEP Download Simplified 4-Stage STEP · Reference
| Ø Diameter | Reduction ratios | Gearhead body length | Rated allowable torque | Backlash |
|---|---|---|---|---|
| 32 mm | 3.5:1–509.1:1 | 28.05–52.95 mm | 3432.3–7845.3 mN·m | ≤ 1.2° |
Custom 32P interface or motor fit? Match my motor · Review my drawing / STEP · Replace / redesign existing gearbox · Prototype → volume
More: Stage-by-stage ratios · Online technical specifications · Mechanical drawing preview · Motor-only datasheets · All 12 models
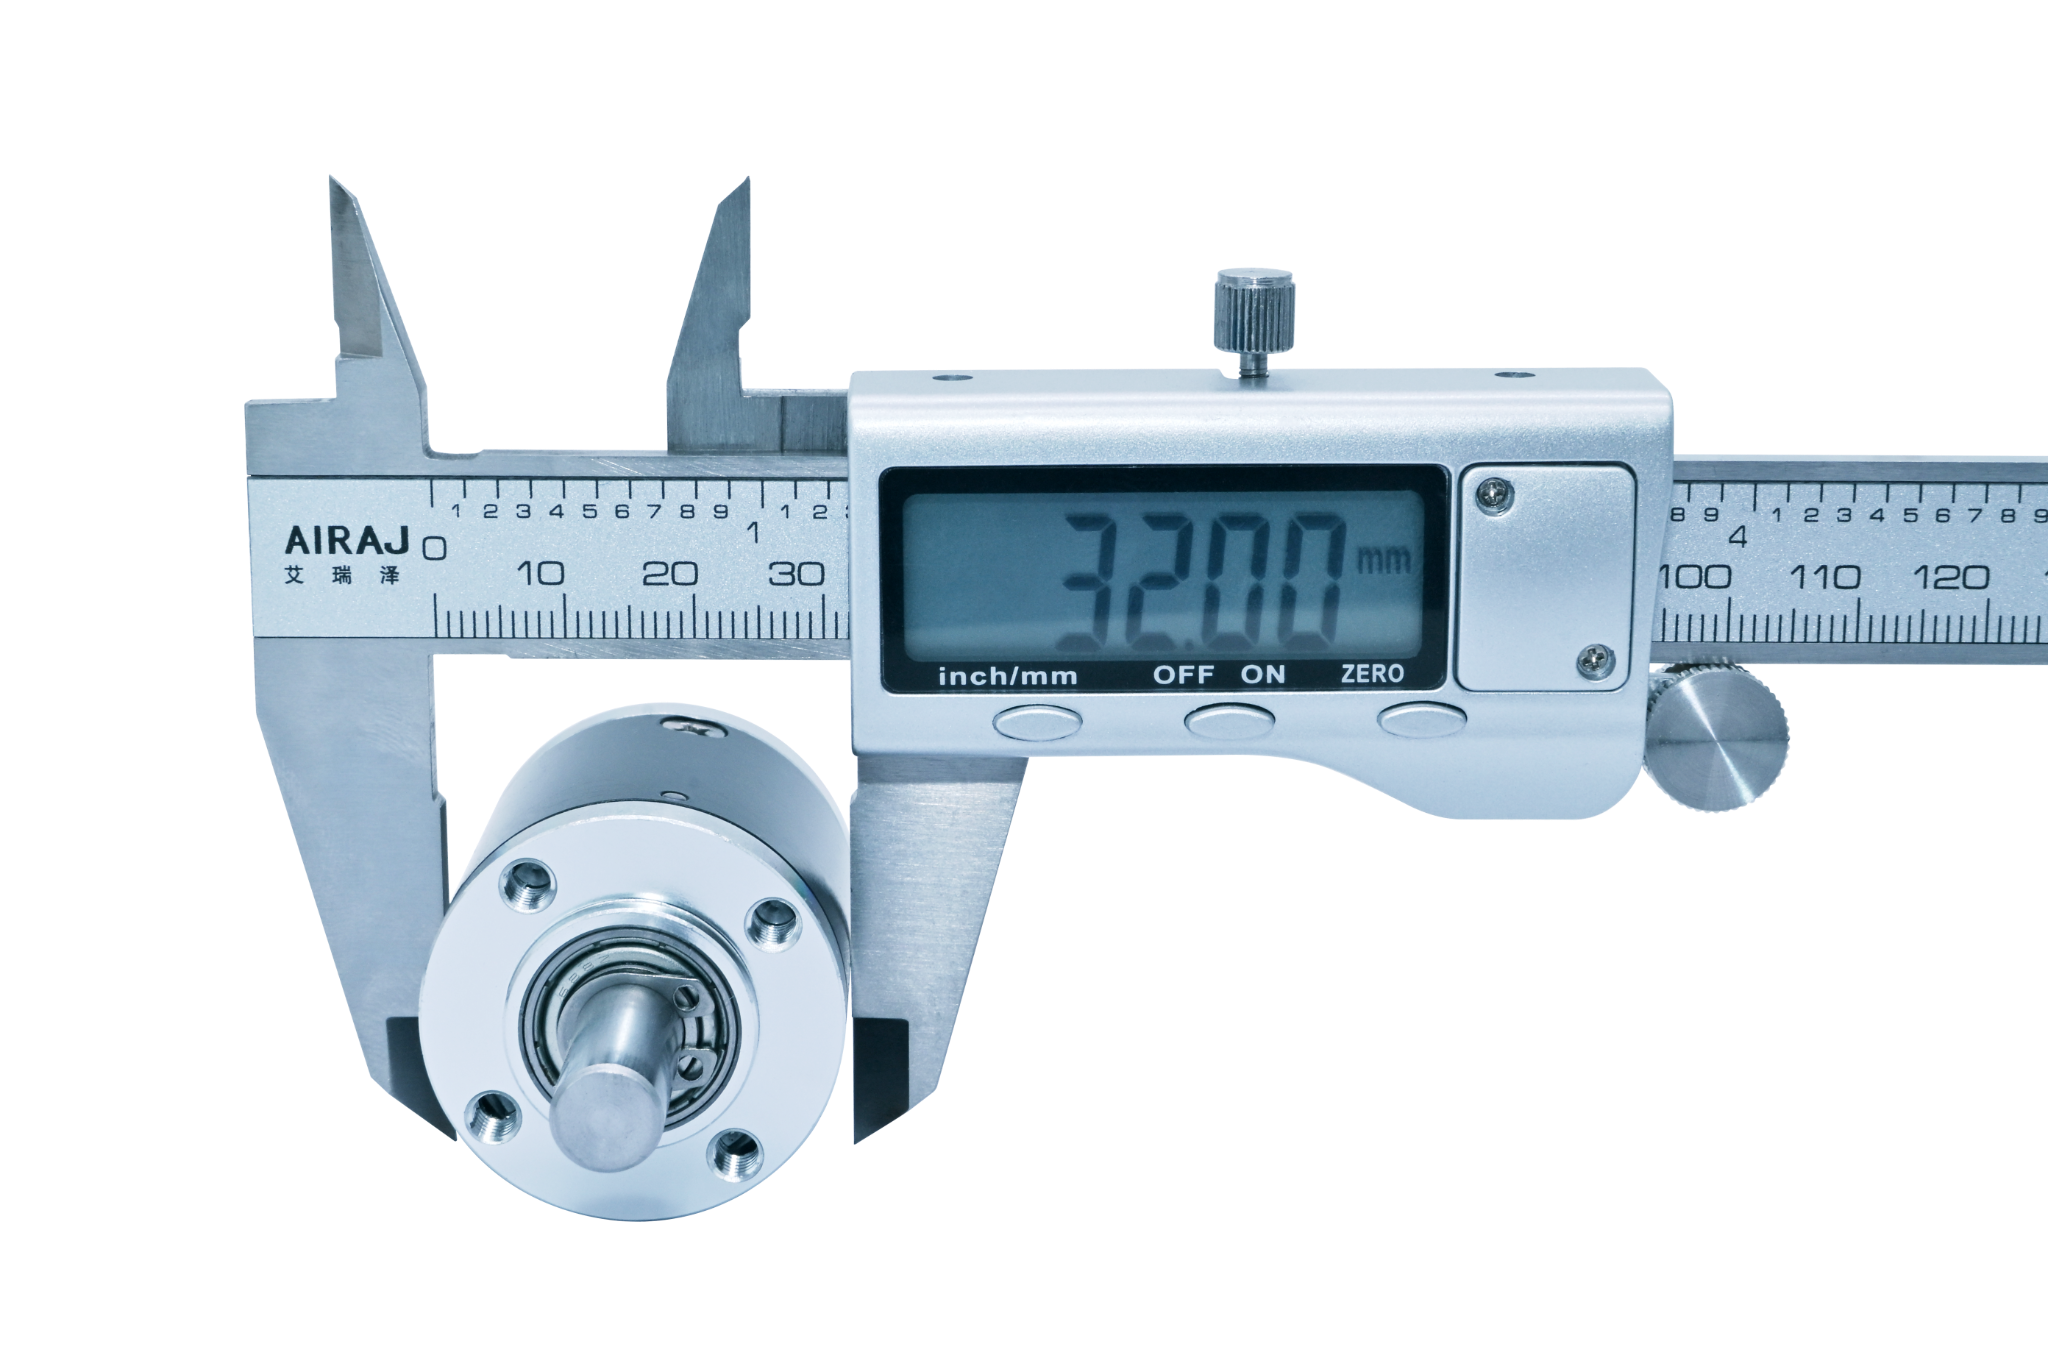
Product Identity
| Item | Description |
|---|---|
| Model | 32P |
| Product type | Miniature precision planetary gearhead (planetary gearbox) |
| Nominal outer diameter | 32 mm |
| Number of stages | 1 to 4 |
| Manufacturing process | Machining |
Key Specifications
| Parameter | Published value |
|---|---|
| Nominal outer diameter | 32 mm |
| Gearhead length range | 28.05–52.95 mm |
| Reduction ratio range | 3.5:1–509.1:1 |
| Rated allowable torque range | 3432.3–7845.3 mN·m |
| Maximum momentary torque range | 6864.7–15690.6 mN·m |
| Efficiency range | 66–90% |
| Backlash at no load | ≤ 1.2° |
| Permissible gearhead input speed, continuous operation | Motor/configuration dependent; confirm selected operating point |
| Adapted DC motor voltage | 3–36 VDC |
| Adapted DC motor power | below 100 W |
| Housing material | Steel |
| Gear material | Steel |
| Output bearing | Ball Bearing |
| Radial load, 10 mm from flange | <= 8.0 kgf |
| Shaft axial load | <= 3.5 kgf |
| Radial play of shaft | <= 0.04 mm |
| Thrust play of shaft | <= 0.3 mm |
| Operating temperature range | -40 to 120 C |
Maximum momentary torque is not a continuous working rating.
The current public specification uses ≤ 1.2° as the backlash-at-no-load value.
Stage, Ratio and Performance Table
| Stages | Gearhead length L | Available reduction ratios | Rated allowable torque | Maximum momentary torque | Efficiency |
|---|---|---|---|---|---|
| 1 | 28.05 mm | 3.5 / 4 / 4.75 | 3432.3 mN·m | 6864.7 mN·m | 90% |
| 2 | 36.35 mm | 12.2 / 14 / 16 / 16.6 / 19 / 22.6 | 4903.3 mN·m | 9806.6 mN·m | 80% |
| 3 | 44.65 mm | 42.9 / 49 / 56 / 58.2 / 64 / 66.5 / 76 / 79 / 90.2 / 107.2 | 6374.3 mN·m | 12748.6 mN·m | 73% |
| 4 | 52.95 mm | 150.1 / 171.5 / 196 / 203.7 / 224 / 232.7 / 256 / 266 / 276.4 / 304 / 315.9 / 361 / 375.1 / 428.7 / 509.1 | 7845.3 mN·m | 15690.6 mN·m | 66% |
Motor Compatibility
The adapted-motor sheet identifies DC motors with a nominal voltage of 3–36 VDC and power below 100 W. If the motor cannot meet the gearhead installation requirements, the motor and gearhead interface details need to be negotiated separately.
These are adapted-motor conditions, not an electrical voltage or power rating for the mechanical gearhead itself. Confirm the motor shaft, mounting interface, input speed, duty cycle and operating point for the selected gearhead ratio.
Dimensions and Interface
The published drawing shows a 32 mm body diameter and stage-dependent gearhead lengths of 28.05, 36.35, 44.65 and 52.95 mm.
The current public STEP reference is a 4-stage reference corresponding to the 52.95 mm gearhead-body length. It must not be treated as a universal 1-4 stage STEP model.
Publicly released interface information includes:
- Output side: 4 x M3 threaded holes, depth 4.5 mm
- Output mounting-hole center radius: 9.8 mm
- Output-side reference diameter: 26.0 +/- 0.1 mm
- Nominal output shaft diameter: 8 mm
- Output shaft extension: 21.6 mm (+0.1 / -0.3 mm)
- Keyway width shown on the controlled drawing: 3.0 mm
- Keyway length shown on the controlled drawing: 12.0 mm
- Input side: 2 x dia. 3.1 mm mounting holes
- Opposed input mounting-hole center spacing: 22.0 +/- 0.1 mm
- Central input opening: dia. 13.0 +0.05 / 0 mm
Use the controlled drawing for final tolerances, keyseat definition and production release.
STEP Notes
The Full Assembly STEP is the published original Creo assembly. The Simplified STEP is a separate 4-stage reference for preliminary mechanical packaging. The 32P 2D outline drawing is the original SG01PD32 interface reference. The body length L ±0.3 mm is configuration-dependent; confirm stage, ratio and motor mating dimensions before production.
Back to the 8–42 mm product catalogue
Potential OEM applications (suitability requires engineering review): Robotic arm wrist mechanisms · Humanoid robot auxiliary axes · Quadruped robot joints · Vending and kiosk mechanisms · All applications.
Motor + Gearhead Assembly: Motor matching and custom integration.